
About me
Hi! I am a Ph.D. student in Mechanical Engineering at the University of California, Berkeley. I work in the ICON Lab under Prof. Negar Mehr. My research focuses on robot learning, especially on developing autonomous robots that can work alongside humans and other robots.
Prior to Berkeley, I earned my B.S. in Mechanical Engineering from Yonsei University. During my undergraduate studies, I worked as a research intern in MLCS Lab under Prof. Jongeun Choi, where I worked on MPCs and RL for autonomous driving, as well as visuamotor policy learning for contact-rich manipulation.
Research
My research lies at the intersection of robot learning, control, and foundation models. I study how LLMs can be integrated into robot learning to acquire complex, coordinated robot behaviors. This includes CRAFT, where LLMs coach reinforcement learning through automatically generated curricula for multi-robot coordination, and HuGo, where LLMs directly write whole-body policy code for humanoid loco-manipulation.
In parallel, I explore scalable imitation learning methods, such as diffusion policy and VLAs, that can transfer single-robot expertise to multi-robot settings, where data collection is especially challenging. Ultimately, I aim to develop autonomous systems that can learn efficiently, coordinate intelligently, and operate alongside humans and other robots.
News
| Sep, 2026 | CoHuB, a simulation benchmark for multi-humanoid collaboration, is now available on Arxiv. |
| Sep, 2026 | My new first-authored paper HuGo, on using LLMs as whole-body policy code designers for humanoid loco-manipulation, is now available on Arxiv. |
| Jun, 2026 | Happy to share that CRAFT won the Outstanding Paper Award at the ICRA 2026 Workshop on Scaling Compositional Intelligence for Multi-Agent Robotic Systems. 🏆 |
| Sep, 2025 | I am excited to announce that my first first-authored paper CRAFT is now available in Arxiv. |
| Jul, 2025 | I was selected as one of the best 10 research proposals in the Google-BAIR Commons Annual Workshop. |
| Apr, 2024 | I will start my Ph.D at UC Berkeley, beginning Fall 2024. 🥳 |
Publications
S. Choi, S. Ye, N. Bui, A. Shrivastava, K. Ryu, D. Tirumala, M. Wulfmeier, and N. Mehr
Preprint
H. Park*, J. Chae*, M. Park*, S. Park, H. Yoo, S. Choi, S. Yoo, J. Seo, S. Idrees, J. Hyun, J. Lee, R. Horowitz, Y. Lee, and J. Choi (*Equal contribution)
Preprint

S. Choi*, K. Ryu*, J. Ock, and N. Mehr (*Equal contribution)
Preprint, Outstanding Paper Award in ICRA 2026 Workshop on Scaling Compositional Intelligence for Multi-Agent Robotic Systems
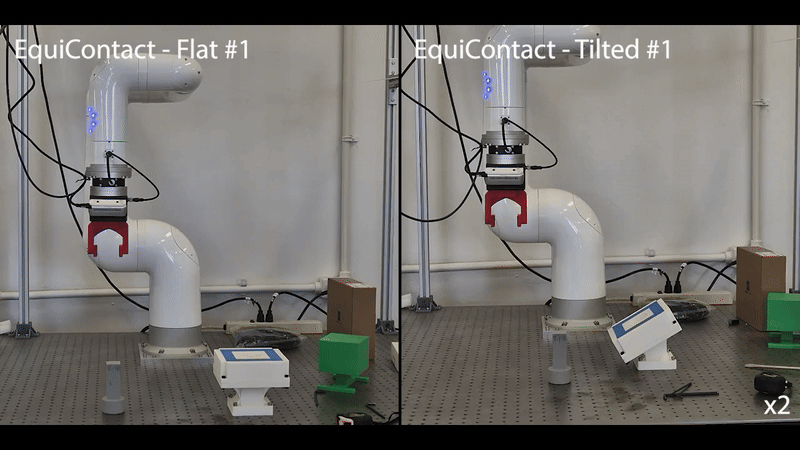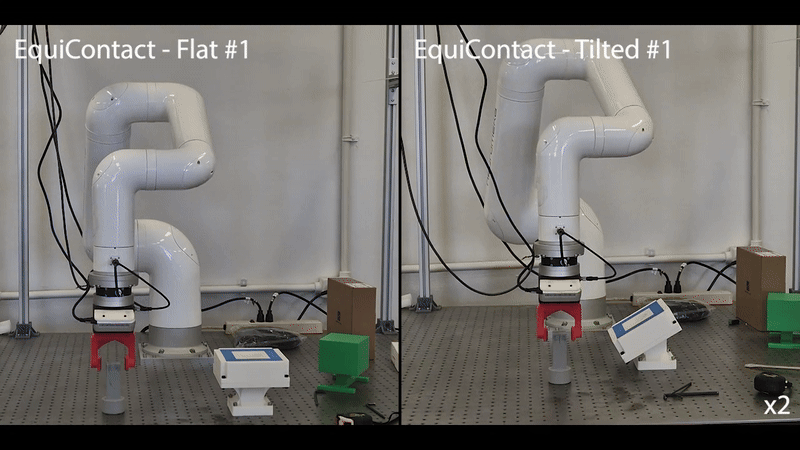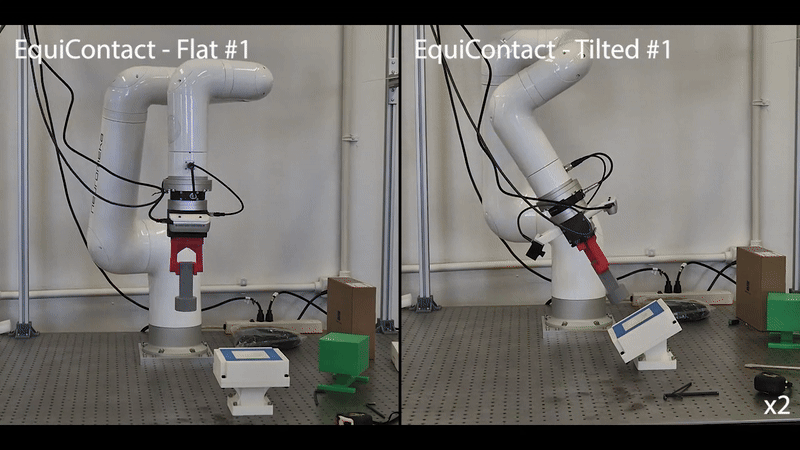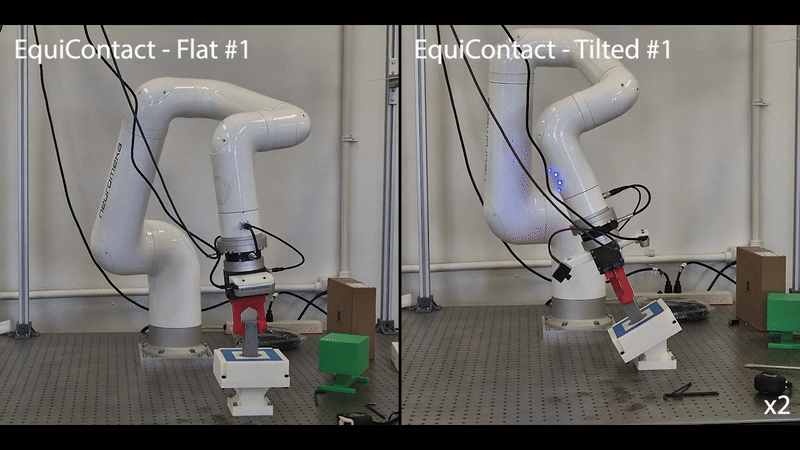
J. Seo, A. Kruthiventy, S. Lee, M. Teng, X. Zhang, S. Choi, J. Choi, and R. Horowitz
Preprint
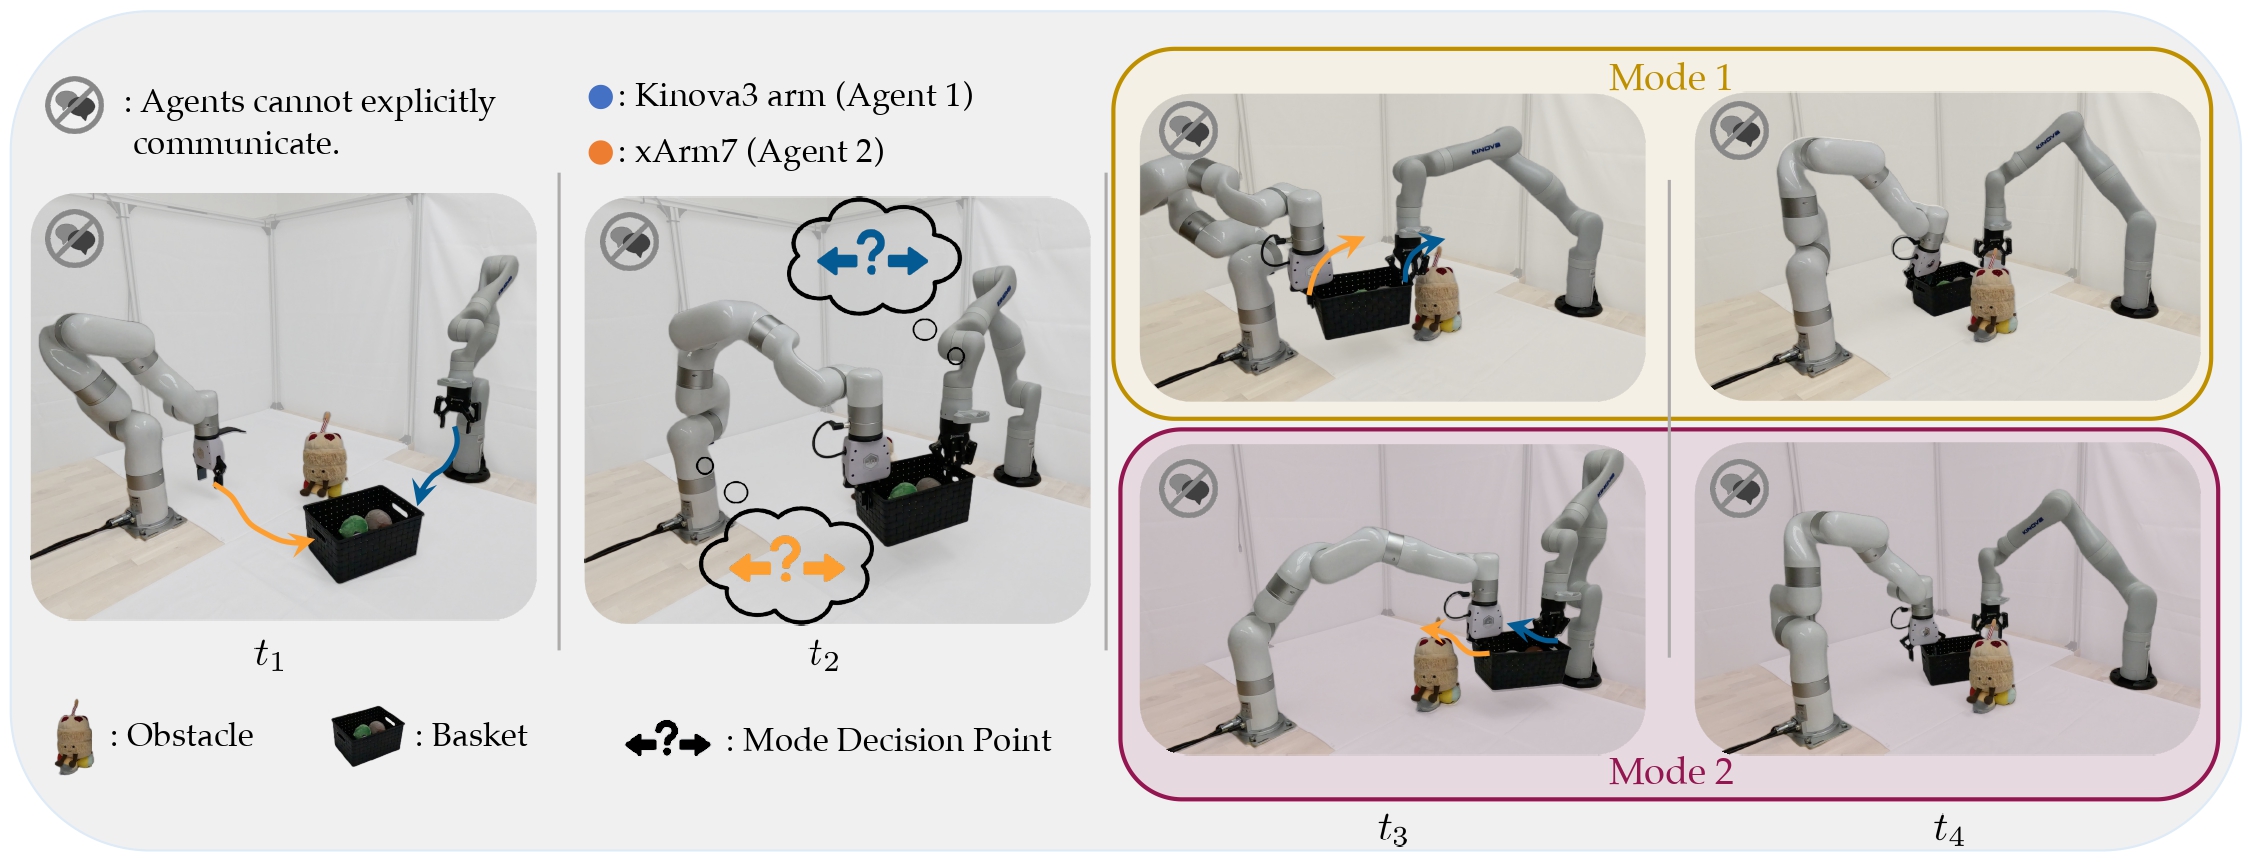
D. Dong*, M. Bhatt*, S. Choi, and N. Mehr (*Equal contribution)
ICRA 2026